My research interests lie in embodied intelligence, with a focus on vision-language-action models, predictive world models, and efficient 3D scene understanding for autonomous systems. Looking ahead, I aim to advance Physical AI by unifying vision-language-action models with world models, enabling agents to learn through interaction in differentiable and interactive systems.
I expect to graduate in December 2026 and am actively seeking postdoctoral opportunities beginning in January 2027. I would be delighted to connect with researchers and groups working on related topics.
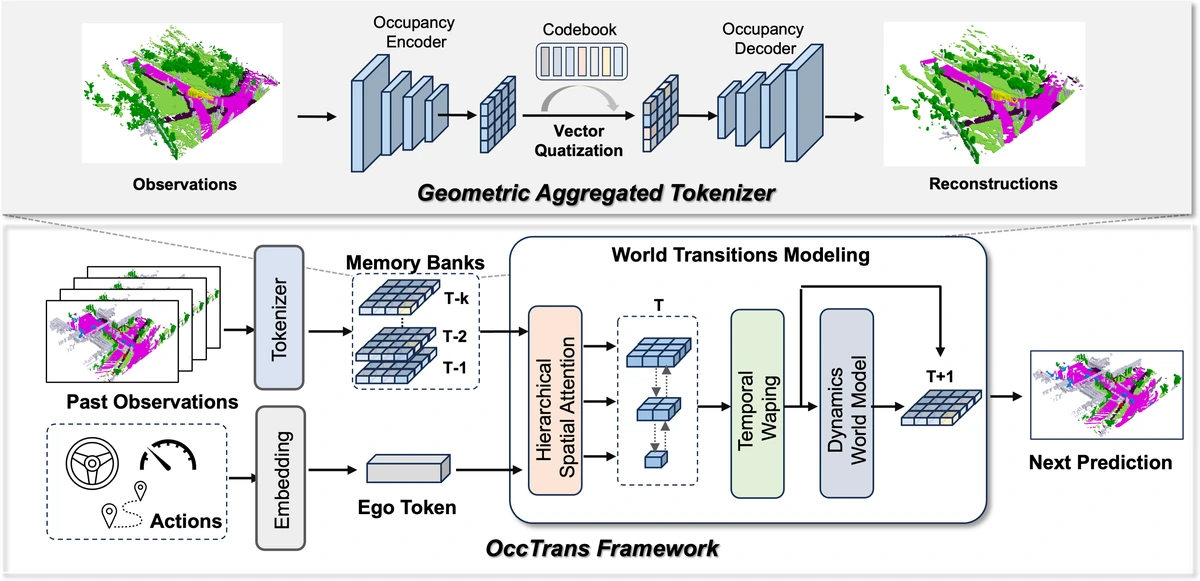
Separating changes caused by the moving observer from changes in the scene lets an occupancy world model learn residual dynamics and preserve consistency over longer forecasts.
occupancy world modelsego-motion compensationtemporal dynamics
Pin Tang, Zhongdao Wang, Guoqing Wang, Xiangxuan Ren, Chao Ma
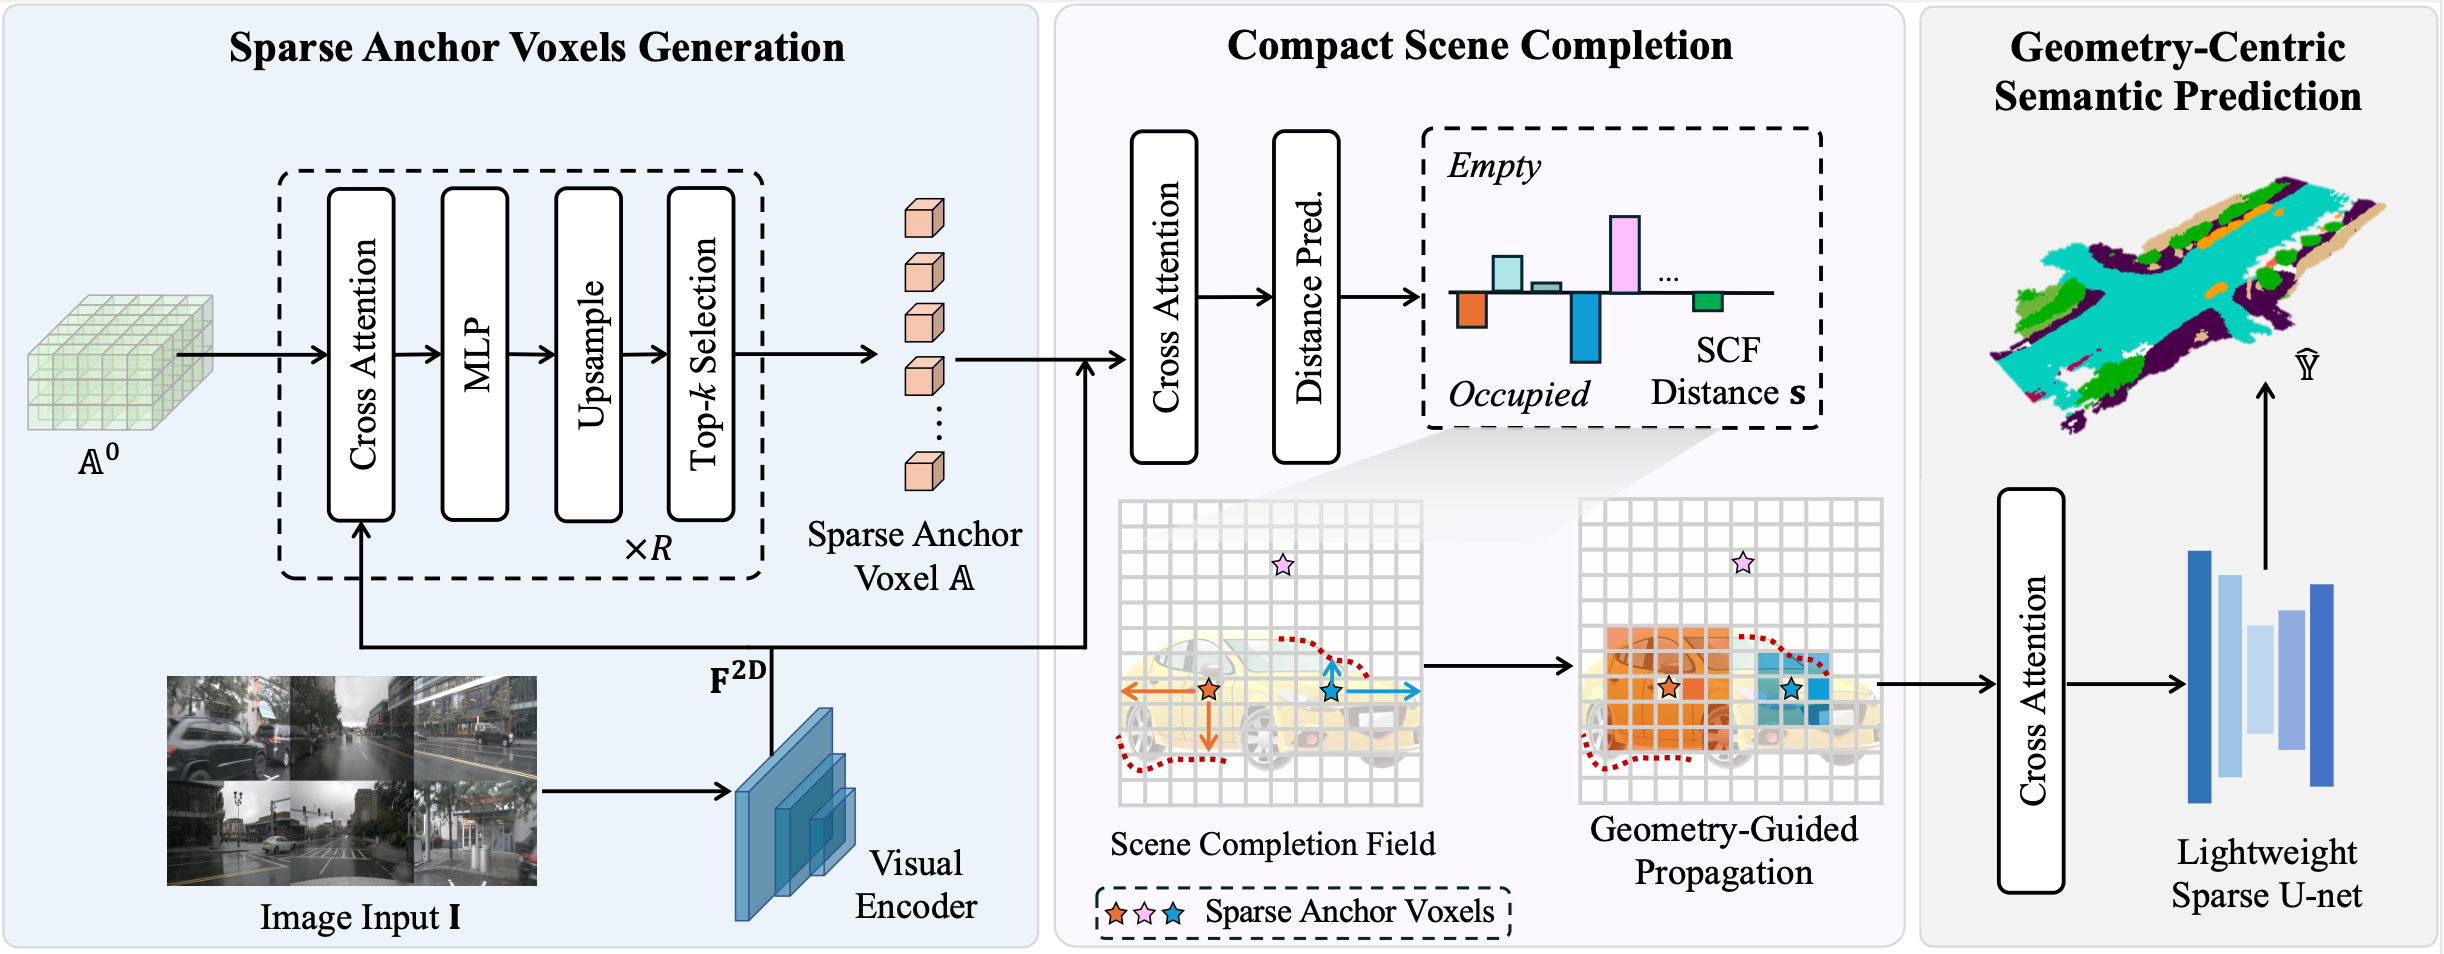
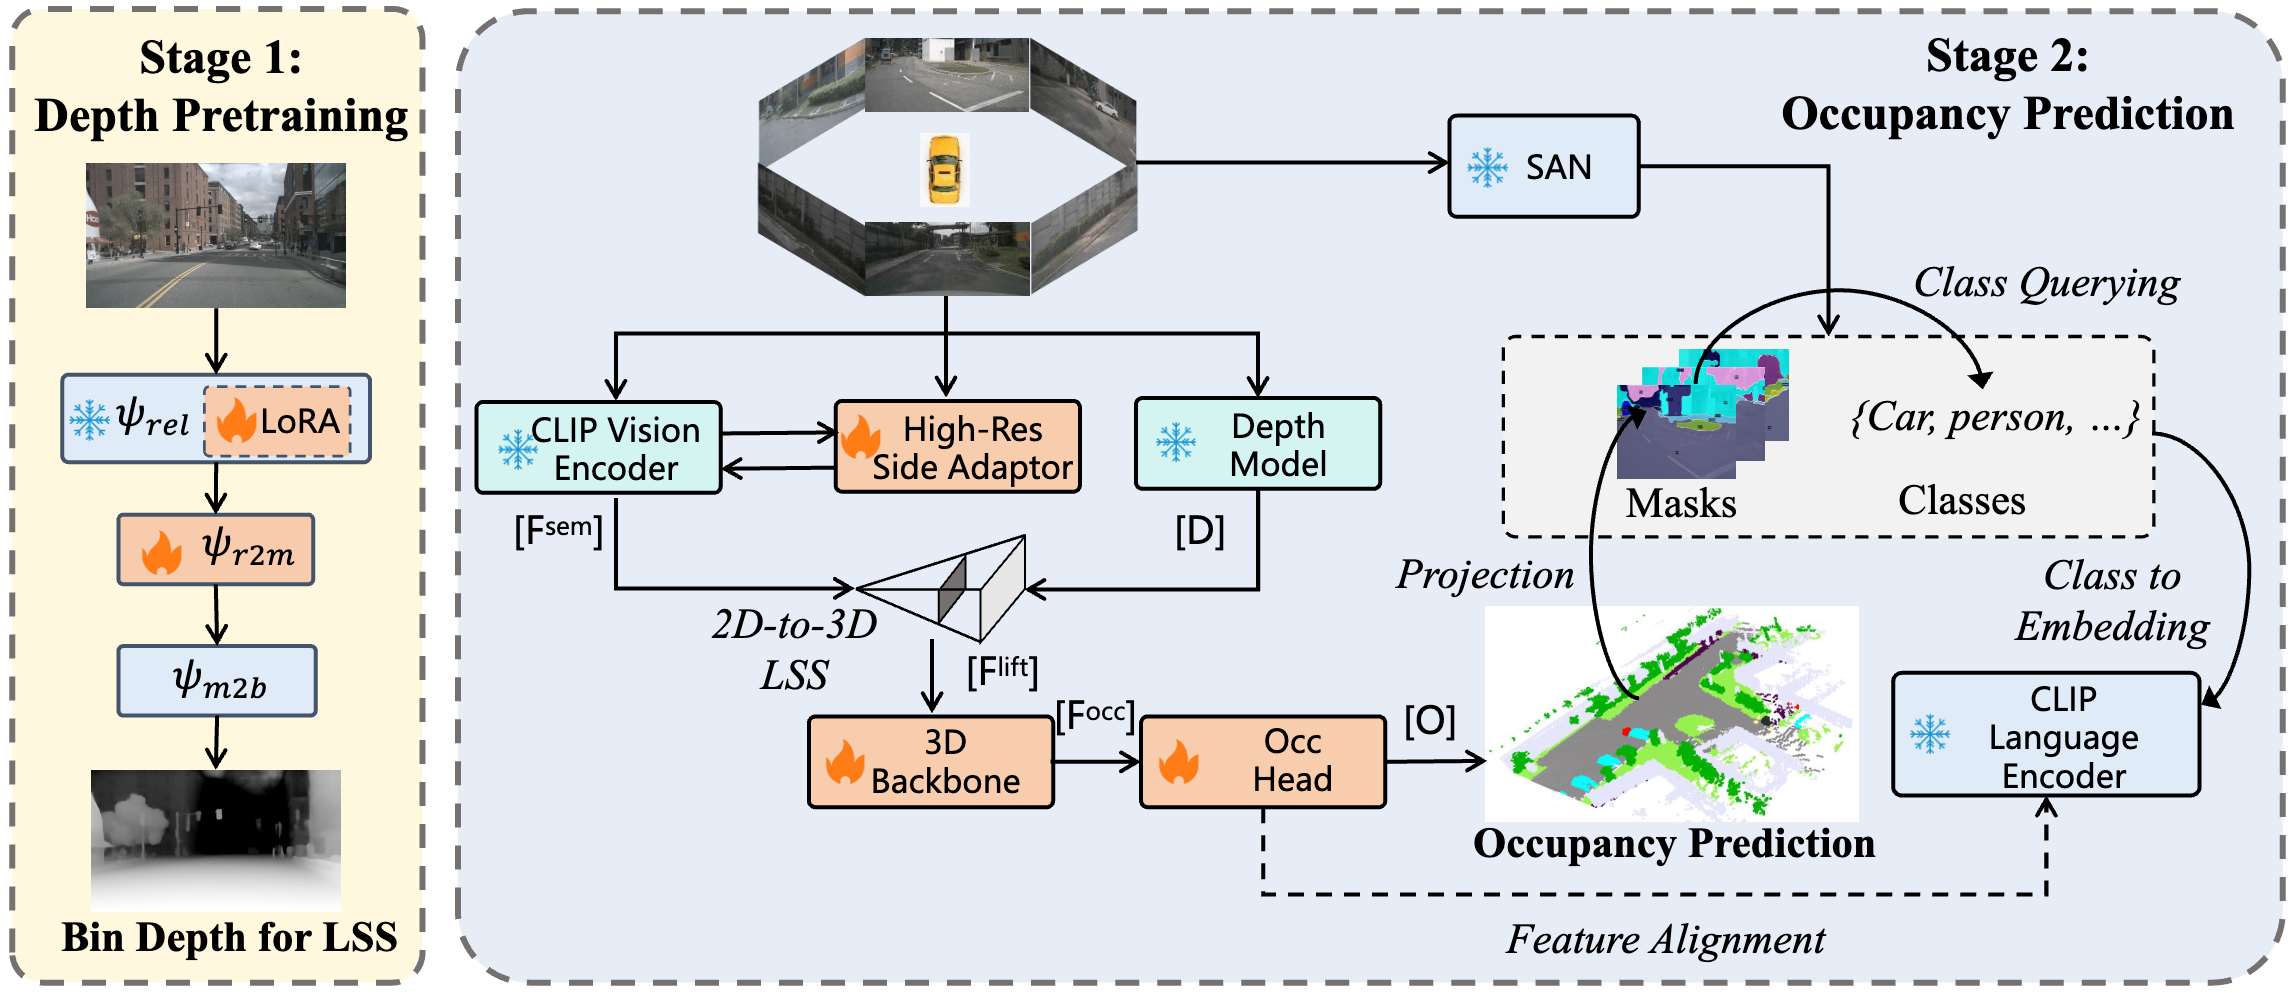
Separates scene completion from semantic prediction using sparse signed-distance fields and geometry-guided propagation for accurate, efficient occupancy prediction.